Robotics
Quadruped Robotics
I designed and built a four-legged robot, then wrote the control logic to coordinate its twelve joints. This is where the maths has to work in the real world.
My role
Design and engineering
The disciplines
12-DOF motion / Inverse kinematics / Embedded systems
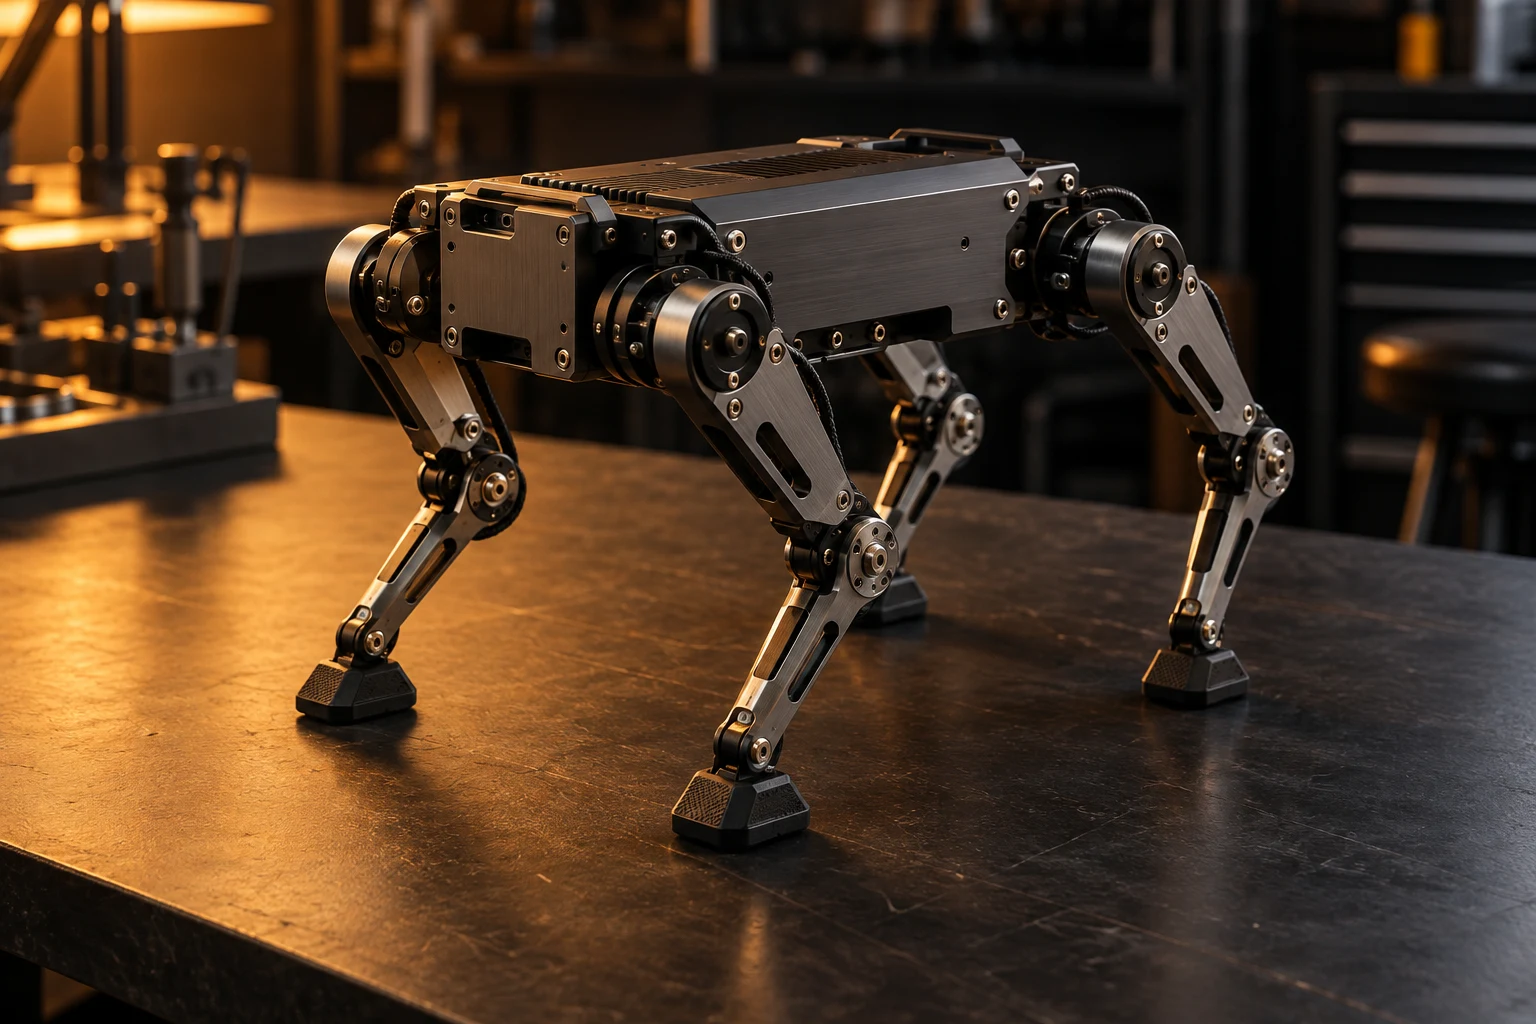
From geometry to movement
A quadruped turns a geometric problem into a physical one: each foot position must become coordinated joint movement.
What I built
I designed and manufactured the 12-DOF robot, wrote its inverse-kinematics algorithm, and connected the servo drivers to a microcontroller.
Getting the legs to agree
Each desired foot position becomes a set of joint angles. The embedded controller then sends those commands to the servos, connecting the mechanical design to the code that moves it.